运行前必须先在 config yaml 里改好数据路径;示例数据需从 Google Drive 单独下载;ROS 支持要另装 lidar_odometry_ros_wrapper 仓库
git clone https://github.com/93won/lidar_odometry
cd lidar_odometry
./build.sh 硬件要求按 README 说明
README 未说明具体显存、CPU 或 GPU 型号要求
实时 LiDAR SLAM 系统,在 KITTI 上跑到约 400 FPS,适合需要高速建图定位的工程场景
用 C++ 实现的快速 LiDAR SLAM,从激光雷达点云做里程计与建图,适合机器人、自动驾驶的实时定位需求。
核心能力
- 用两级层次化体素地图预计算 surfel
- 基于李群高斯牛顿的点到面 ICP 配准
- 用自适应 M 估计器 PKO 做鲁棒估计
- 用 LiDAR Iris 做回环检测
- 对应关系可选 surfel O(1) 查找或 KDTree 动态拟合平面
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
暂无 release 数据(可能没有发版,或尚未同步)。
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。
Fast LiDAR SLAM
A high-performance real-time LiDAR SLAM system (~400 FPS on KITTI).
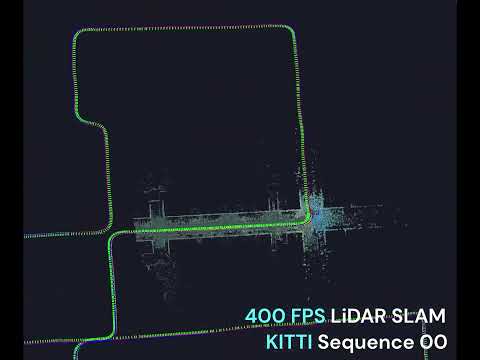
Features
- 2-Level hierarchical voxel map with precomputed surfels
- Point-to-plane ICP with Gauss-Newton optimization on Lie manifold
- Adaptive M-estimator for robust estimation (PKO)
- Loop closure detection with LiDAR Iris
- Configurable correspondence method: Surfel-based (O(1) lookup) or KDTree-based (dynamic plane fitting)
Correspondence Method Selection
use_surfel_correspondence: false # true: O(1) surfel lookup, false: KDTree + plane fitting
- Surfel-based (default): Pre-computed surfels enable O(1) correspondence lookup. Best for outdoor environments with large planar structures.
- KDTree-based: Dynamic plane fitting at query time. Recommended for unstructured environments or narrow indoor spaces where pre-computed surfels may not represent local geometry accurately.
Build
git clone https://github.com/93won/lidar_odometry
cd lidar_odometry
./build.sh
Run
Before run algorithm on a test data do not foget update paths in config yaml files
# KITTI dataset
./build/kitti_lidar_odometry config/kitti.yaml

# MID360 / PLY files
./build/lidar_odometry config/mid360.yaml
Sample Data
ROS Wrapper
https://github.com/93won/lidar_odometry_ros_wrapper
References
@article{choi2025surfel,
  title={Surfel-LIO: Fast LiDAR-Inertial Odometry with Pre-computed Surfels and Hierarchical Z-order Voxel Hashing},
  author={Choi, Seungwon and Park, Dong-Gyu and Hwang, Seo-Yeon and Kim, Tae-Wan},
  journal={arXiv preprint arXiv:2512.03397},
  year={2025}
}

@article{choi2025pko,
  author={Choi, Seungwon and Kim, Tae-Wan},
  journal={IEEE Robotics and Automation Letters},
  title={Probabilistic Kernel Optimization for Robust State Estimation},
  year={2025},
  volume={10},
  number={3},
  pages={2998-3005},
  doi={10.1109/LRA.2025.3536294}
}

@inproceedings{wang2020iris,
  title={LiDAR Iris for Loop-Closure Detection},
  author={Wang, Ying and Sun, Zezhou and Xu, Cheng-Zhong and Sarma, Sanjay and Yang, Jian and Kong, Hui},
  booktitle={IROS},
  year={2020}
}
License
MIT License
ORB_SLAM3
UZ-SLAMLab·C++
开源视觉、视觉惯性与多地图 SLAM 库,支持单目、双目、RGB-D 相机,在室内外场景提供高精度实时定位与建图。
视觉SLAM+4视觉定位 / SLAM
9240+133.2kv1.0-release2024-07-24 08:41 UTC

g2o
RainerKuemmerle·C++
C++ 图优化通用框架,把 SLAM 和视觉定位里的位姿估计建模成图,用非线性最小二乘求解,是后端优化的经典基础设施。
图优化+4视觉定位 / SLAM
34781.2k20241228_git2026-11-09 19:43 UTC
vipe
nv-tlabs·Python
从视频中估计相机位姿、深度和相机内参的 3D 感知引擎,为几何三维重建与空间理解提供基础数据。
视频位姿估计+4视觉定位 / SLAM
2197+10181v1.2.02026-11-05 23:50 UTC
ElasticFusion
mp3guy·C++
实时稠密视觉 SLAM 系统,用 RGB-D 相机在线重建房间级三维场景,适合做实时建图与稠密重建研究。
视觉SLAM+4视觉定位 / SLAM
19335932025-08-03 10:04 UTC