需在 ROS catkin 工作空间内构建,直接 catkin build 前要确认环境已 source;运行 launch 前需自行设置 bag_path 并准备对应数据集;保存地图需调用 /lio_sam_6axis/save_map 服务,地图输出在 LIO-SAM-6AXIS/data 目录。
git clone https://github.com/JokerJohn/LIO_SAM_6AXIS.git
cd LIO_SAM_6AXIS
catkin build 硬件要求按 README 说明
README 未说明显存或 CPU 要求;Docker 运行命令使用 --gpus all,说明需要 NVIDIA GPU 环境。
有 Docker 镜像
基于 LIO-SAM 改造的激光惯性 SLAM 项目,支持 6 轴 IMU 和低成本 GNSS
基于 LIO-SAM 改造的激光惯性 SLAM 方案,支持 6 轴 IMU 和 GNSS 融合,解决低成本 6 轴 IMU 无法直接跑原版 LIO-SAM 的问题。
核心能力
- 支持 6 轴 IMU,在状态估计中利用姿态信息
- 支持低成本 GNSS,无需适配 robot_localization 节点
- 可视化 GPS 约束,便于调试优化过程
- 提供 Dockerfile 与预构建镜像,隔离环境依赖
- 附带多套数据集与传感器适配配置示例
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
暂无 release 数据(可能没有发版,或尚未同步)。
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。

LIO_SAM_6AXIS
LIO_SAM_6AXIS is an open-source SLAM project based on the project LIO_SAM that has been modified to support a wider range of sensors. It includes support for a 6-axis IMU and low-cost GNSS, making it easier to adapt for your own sensor setup.
Features
LIO_SAM_6AXIS includes the following features:
- Support for a 6-axis IMU: This allows you to use orientation information in state estimation, improving the accuracy of your results.
- Support for low-cost GNSS: By eliminating the need to adapt for the robot_localization node, this feature makes it easier to integrate GNSS into your SLAM system.
- GPS constraint visualization: This feature helps with debugging by allowing you to visualize the GPS constraints that are being used in the optimization.
Latest News(2025-05-23)
- Currently, it is challenging to make significant improvements and enhancements based on this framework. We strongly recommend using MS-Mapping for mapping with better accuracy and robustness; you only need to set
useMultiMode = false. Additionally, multi-session mapping is supported, and a Docker environment is available for configuration.

Getting Started
To get started with LIO_SAM_6AXIS, follow these steps:
- Clone the repository:
git clone https://github.com/JokerJohn/LIO_SAM_6AXIS.git
- Install the dependencies:
cd LIO_SAM_6AXIS
catkin build
- Launch the roslaunch file for your sensor setup:
# set your bag_path here
roslaunch lio_sam_6axis test_vlp16.launch
For more information on how to use LIO_SAM_6AXIS, see the video tutorial and documentation.
- finally, save your point cloud map.
# map is in the LIO-SAM-6AXIS/data
rosservice call /lio_sam_6axis/save_map
- for docker support.
Dockerfile is for people who don't want to break their own environment.
# please cd the folder which have Dockerfile first, approximately 10mins based on your internet and CPU
docker build -t zhangkin/lio_sam_6axis .

docker run -it --net=host --gpus all --name lio_sam_6axis zhangkin/lio_sam_6axis /bin/zsh

# OR -v to link the folder from your computer into container (your_computer_loc:container_loc)
docker run -it --net=host --gpus all --name lio_sam_6axis -v /home/kin/bag_data:/home/xchu/data/ramlab_dataset zhangkin/lio_sam_6axis /bin/zsh

# in the container
catkin build
source devel/setup.zsh

# with dataset download and linked ==> please see more usage in previous section
roslaunch lio_sam_6axis ouster128_indoors.launch

# 对于在内地的同学,可以换源`dockerhub`后,直接拉取:
docker pull zhangkin/lio_sam_6axis
Documentation
The documentation for LIO_SAM_6AXIS can be found in the doc directory of the repository. It includes instructions on how to adapt the code for your own sensors and lidars.
Dataset and Adaptation
LIO_SAM_6AXIS is compatible with a range of datasets and sensor setups. To help you get started, we have included a table that lists some of the datasets and sensors that have been tested with LIO_SAM_6AXIS.
| Dataset | Description | Sensors | Download Links | Ground Truth | Comments |
|---|---|---|---|---|---|
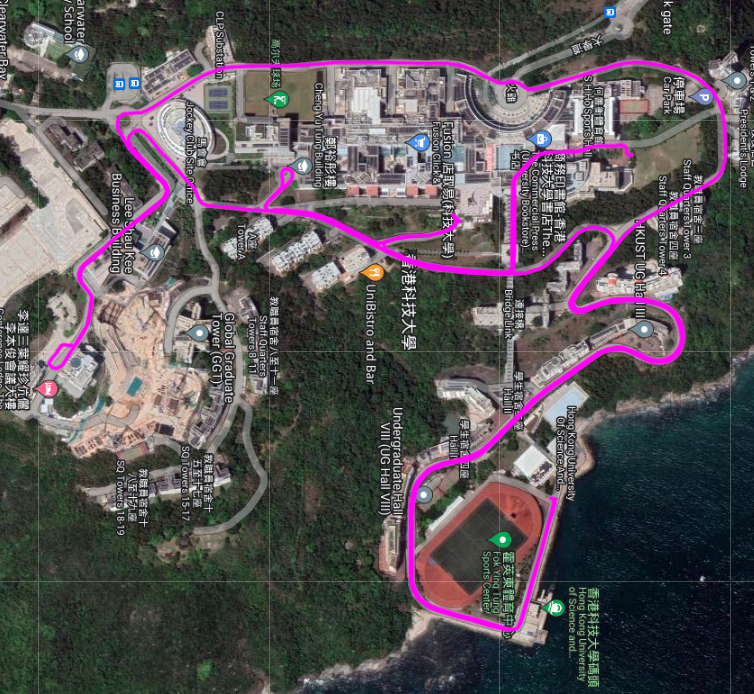
| hkust_20201105full |  | VLP-16, STIM300 IMU, left camera, normal GPS | Dropbox, BaiduNetdisk (password: m8g4) | GT (password:123) | About 10 km outdoor, see this doc |
| HILTI DATASET 2022 |  | Hesai32 lidar, low-cost IMU, 5 Fisher Eye cameras | Download | The config/params_pandar.yaml is prepared for the HILTI sensors kit | |
| FusionPortable DATASET |  | Ouster OS1-128, STIM300 IMU, stereo camera | Download | GT | Indoors. When you download this compressed data, remember to execute the following command: rosbag decompress 20220216_garden_day_ref_compressed.bag |
| Multimodal Dataset |  | MS1600 | Download | Multimodal Dataset from Harsh Sub-Terranean Environment with Aerosol Particles for Frontier Exploration | |
| MS |  | Pandar-XT 32 | Download | GT | With accurate RTK trajectory and ground truth map |
| Newer college |  | Ouster128-OS1 + Integrated IMU | Download | GT | Campus scene with ground truth map. |
Related Package
1. LIO-SAM-6AXIS-UrbanNav
- LIO_SAM 6轴IMU适配香港城市数据集UrbanNav,并给出添加GPS约束和不加GPS约束的结果
2. LIO-SAM-6AXIS-INTENSITY
- integrate LIO-SAM and Imaging_lidar_place_recognition to achieve better mapping and localization result for SLAM system.
Credits
We would like to thank TixiaoShan for creating the LIO_SAM project that served as the foundation for this work.
Acknowledgments
Our deep gratitude goes to pedrotomas27, Guoqing Zhang, Jianhao Jiao, Jin Wu, and Qingwen Zhang for their invaluable contributions to this project. A special mention goes to the LIO_SAM for laying the groundwork for our efforts. We also thank the open-source community, whose relentless pursuit of SLAM technology advancement has made this project possible.
ORB_SLAM3
UZ-SLAMLab·C++
开源视觉、视觉惯性与多地图 SLAM 库,支持单目、双目、RGB-D 相机,在室内外场景提供高精度实时定位与建图。
视觉SLAM+4视觉定位 / SLAM
9241+143.2kv1.0-release2024-07-24 08:41 UTC

g2o
RainerKuemmerle·C++
C++ 图优化通用框架,把 SLAM 和视觉定位里的位姿估计建模成图,用非线性最小二乘求解,是后端优化的经典基础设施。
图优化+4视觉定位 / SLAM
34781.2k20241228_git2026-11-09 19:43 UTC
vipe
nv-tlabs·Python
从视频中估计相机位姿、深度和相机内参的 3D 感知引擎,为几何三维重建与空间理解提供基础数据。
视频位姿估计+4视觉定位 / SLAM
2198+11181v1.2.02026-11-05 23:50 UTC
ElasticFusion
mp3guy·C++
实时稠密视觉 SLAM 系统,用 RGB-D 相机在线重建房间级三维场景,适合做实时建图与稠密重建研究。
视觉SLAM+4视觉定位 / SLAM
19335932025-08-03 10:04 UTC