需 Python 3.13.x 及 NumPy、SciPy、Matplotlib、cvxpy 依赖;示例需在各自目录下单独执行脚本;用 conda 时改用 requirements/environment.yml 创建环境

PythonRobotics
AtsushiSakai活跃维护用 Python 实现机器人算法的示例代码与配套教材,覆盖定位、建图、路径规划、控制等模块,适合边跑可视化动画边学自动驾驶与自主导航。
Python sample codes and textbook for robotics algorithms.
暂无版本30,885star +12 / 7 天7,440fork同步于 2026-11-10 05:20 UTC
git clone https://github.com/AtsushiSakai/PythonRobotics.git
pip install -r requirements/requirements.txt 硬件要求按 README 说明
README 未说明,示例基于 NumPy、SciPy、Matplotlib 运行,未提及 GPU 或显存要求
支持 Apple Silicon
用 Python 实现并讲解机器人定位、建图、SLAM、路径规划与控制的算法示例集
用 Python 实现机器人算法的示例代码与配套教材,覆盖定位、建图、路径规划、控制等模块,适合边跑可视化动画边学自动驾驶与自主导航。
核心能力
- 每个算法配可运行示例与动画演示
- 覆盖 EKF、粒子滤波、ICP、FastSLAM 等定位建图算法
- 包含 Dijkstra、A*、RRT*、状态栅格等路径规划
- 提供 Stanley、LQR、MPC 等路径跟踪控制示例
- 配套在线教材讲解各算法数学背景
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
这个条目还没有人工点评。如果它对你很有用,欢迎到 提交仓库 页写下你的使用经验。
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。
暂无 release 数据(可能没有发版,或尚未同步)。
PythonRobotics


Python codes and textbook for robotics algorithm.
Table of Contents
- What is this?
- Requirements
- Documentation
- How to use
- Localization
- Mapping
- SLAM
- Path Planning
- Path Tracking
- Arm Navigation
- Aerial Navigation
- Bipedal
- License
- Use-case
- Contribution
- Citing
- Support
- Sponsors
- Authors
What is PythonRobotics?
PythonRobotics is a Python code collection and a textbook of robotics algorithms.
Features:
-
Easy to read for understanding each algorithm's basic idea.
-
Widely used and practical algorithms are selected.
-
Minimum dependency.
See this documentation
or this Youtube video:
or this paper for more details:
Requirements to run the code
For running each sample code:
For development:
-
pytest (for unit tests)
-
pytest-xdist (for parallel unit tests)
-
mypy (for type check)
-
sphinx (for document generation)
-
pycodestyle (for code style check)
Documentation (Textbook)
This README only shows some examples of this project.
If you are interested in other examples or mathematical backgrounds of each algorithm,
You can check the full documentation (textbook) online: Welcome to PythonRobotics’s documentation! — PythonRobotics documentation
All animation gifs are stored here: AtsushiSakai/PythonRoboticsGifs: Animation gifs of PythonRobotics
How to use
-
Clone this repo.
git clone https://github.com/AtsushiSakai/PythonRobotics.git -
Install the required libraries.
-
using conda :
conda env create -f requirements/environment.yml -
using pip :
pip install -r requirements/requirements.txt
-
Execute python script in each directory.
-
Add star to this repo if you like it :smiley:.
Localization
Extended Kalman Filter localization
Reference
GPS/IMU Fusion Localization with Bias Estimation
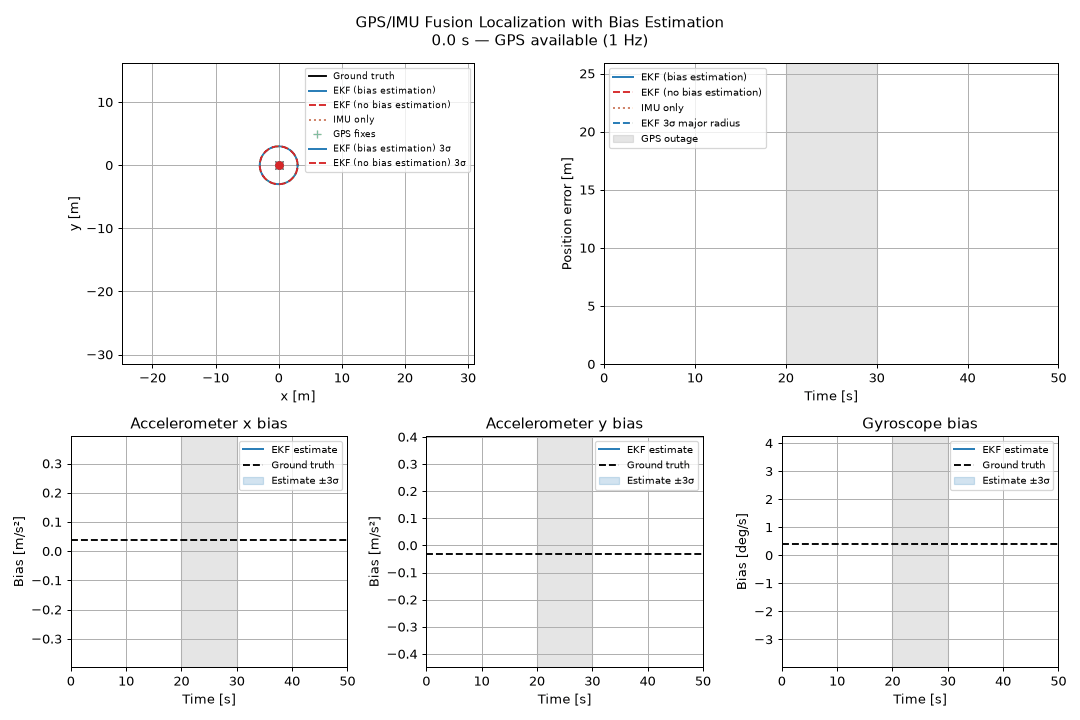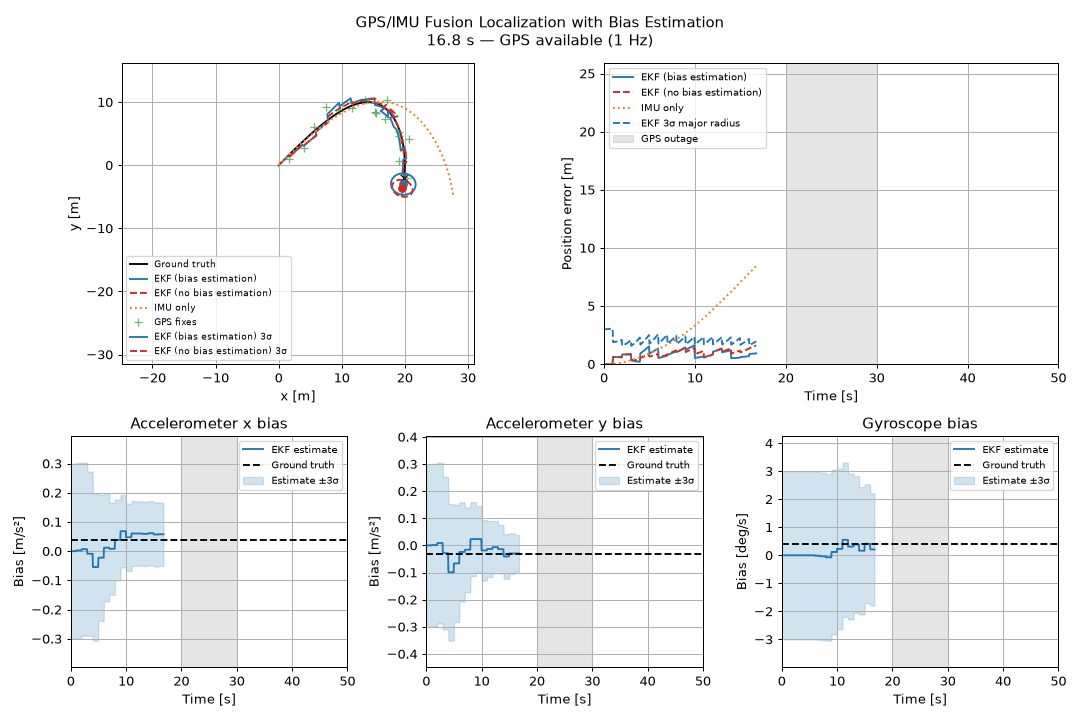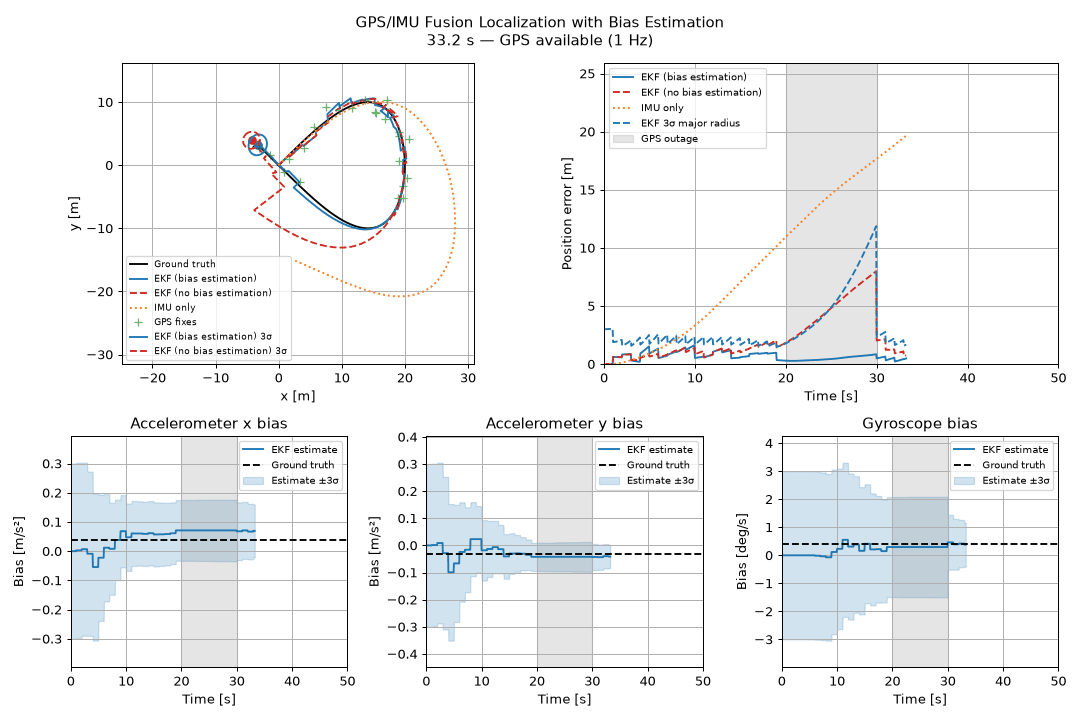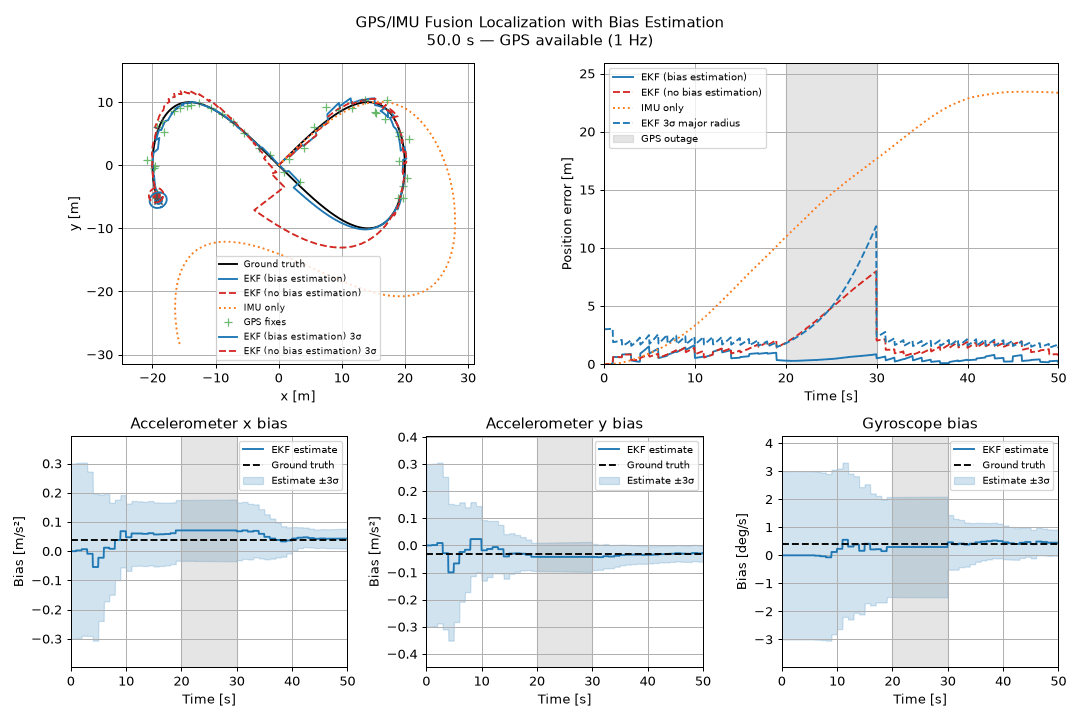
An extended Kalman filter fuses body-frame accelerometer and gyroscope readings with lower-rate GPS positions, estimates sensor biases, and continues inertial prediction during a temporary GPS outage. The animation compares it with an EKF without bias estimation and IMU-only dead reckoning using the same sensor measurements. It also plots the accelerometer and gyroscope bias estimates against their true values, with covariance-derived 3σ position ellipses and bias uncertainty bands.
Particle filter localization

This is a sensor fusion localization with Particle Filter(PF).
The blue line is true trajectory, the black line is dead reckoning trajectory,
and the red line is an estimated trajectory with PF.
It is assumed that the robot can measure a distance from landmarks (RFID).
These measurements are used for PF localization.
Reference
Histogram filter localization

This is a 2D localization example with Histogram filter.
The red cross is true position, black points are RFID positions.
The blue grid shows a position probability of histogram filter.
In this simulation, x,y are unknown, yaw is known.
The filter integrates speed input and range observations from RFID for localization.
Initial position is not needed.
Reference
Mapping
Gaussian grid map
This is a 2D Gaussian grid mapping example.

Ray casting grid map
This is a 2D ray casting grid mapping example.

Lidar to grid map
This example shows how to convert a 2D range measurement to a grid map.

k-means object clustering
This is a 2D object clustering with k-means algorithm.

Rectangle fitting
This is a 2D rectangle fitting for vehicle detection.

SLAM
Simultaneous Localization and Mapping(SLAM) examples
Iterative Closest Point (ICP) Matching
This is a 2D ICP matching example with singular value decomposition.
It can calculate a rotation matrix, and a translation vector between points and points.

Reference
FastSLAM 1.0
This is a feature based SLAM example using FastSLAM 1.0.
The blue line is ground truth, the black line is dead reckoning, the red line is the estimated trajectory with FastSLAM.
The red points are particles of FastSLAM.
Black points are landmarks, blue crosses are estimated landmark positions by FastSLAM.

Reference
Path Planning
Dynamic Window Approach
This is a 2D navigation sample code with Dynamic Window Approach.

Grid based search
Dijkstra algorithm
This is a 2D grid based the shortest path planning with Dijkstra's algorithm.

In the animation, cyan points are searched nodes.
A* algorithm
This is a 2D grid based the shortest path planning with A star algorithm.

In the animation, cyan points are searched nodes.
Its heuristic is 2D Euclid distance.
D* algorithm
This is a 2D grid based the shortest path planning with D star algorithm.

The animation shows a robot finding its path avoiding an obstacle using the D* search algorithm.
Reference
D* Lite algorithm
This algorithm finds the shortest path between two points while rerouting when obstacles are discovered. It has been implemented here for a 2D grid.

The animation shows a robot finding its path and rerouting to avoid obstacles as they are discovered using the D* Lite search algorithm.
Refs:
Potential Field algorithm
This is a 2D grid based path planning with Potential Field algorithm.

In the animation, the blue heat map shows potential value on each grid.
Reference
Grid based coverage path planning
This is a 2D grid based coverage path planning simulation.

Particle Swarm Optimization (PSO)
This is a 2D path planning simulation using the Particle Swarm Optimization algorithm.

PSO is a metaheuristic optimization algorithm inspired by bird flocking behavior. In path planning, particles explore the search space to find collision-free paths while avoiding obstacles.
The animation shows particles (blue dots) converging towards the optimal path (yellow line) from start (green area) to goal (red star).
References
State Lattice Planning
This script is a path planning code with state lattice planning.
This code uses the model predictive trajectory generator to solve boundary problem.
Reference
Biased polar sampling

Lane sampling

Probabilistic Road-Map (PRM) planning

This PRM planner uses Dijkstra method for graph search.
In the animation, blue points are sampled points,
Cyan crosses means searched points with Dijkstra method,
The red line is the final path of PRM.
Reference
Rapidly-Exploring Random Trees (RRT)
RRT*

This is a path planning code with RRT*
Black circles are obstacles, green line is a searched tree, red crosses are start and goal positions.
Reference
RRT* with reeds-shepp path

Path planning for a car robot with RRT* and reeds shepp path planner.
LQR-RRT*
This is a path planning simulation with LQR-RRT*.
A double integrator motion model is used for LQR local planner.

Reference
Quintic polynomials planning
Motion planning with quintic polynomials.

It can calculate a 2D path, velocity, and acceleration profile based on quintic polynomials.
Reference
Reeds Shepp planning
A sample code with Reeds Shepp path planning.

Reference
LQR based path planning
A sample code using LQR based path planning for double integrator model.

Optimal Trajectory in a Frenet Frame

This is optimal trajectory generation in a Frenet Frame.
The cyan line is the target course and black crosses are obstacles.
The red line is the predicted path.
Reference
-
Optimal Trajectory Generation for Dynamic Street Scenarios in a Frenet Frame
-
Optimal trajectory generation for dynamic street scenarios in a Frenet Frame
Path Tracking
move to a pose control
This is a simulation of moving to a pose control

Reference
Stanley control
Path tracking simulation with Stanley steering control and PID speed control.

Reference
Rear wheel feedback control
Path tracking simulation with rear wheel feedback steering control and PID speed control.

Reference
Linear–quadratic regulator (LQR) speed and steering control
Path tracking simulation with LQR speed and steering control.

Reference
Model predictive speed and steering control
Path tracking simulation with iterative linear model predictive speed and steering control.
Reference
Nonlinear Model predictive control with C-GMRES
A motion planning and path tracking simulation with NMPC of C-GMRES

Reference
Arm Navigation
N joint arm to point control
N joint arm to a point control simulation.
This is an interactive simulation.
You can set the goal position of the end effector with left-click on the plotting area.

In this simulation N = 10, however, you can change it.
Arm navigation with obstacle avoidance
Arm navigation with obstacle avoidance simulation.

Aerial Navigation
drone 3d trajectory following
This is a 3d trajectory following simulation for a quadrotor.

rocket powered landing
This is a 3d trajectory generation simulation for a rocket powered landing.

Reference
Bipedal
bipedal planner with inverted pendulum
This is a bipedal planner for modifying footsteps for an inverted pendulum.
You can set the footsteps, and the planner will modify those automatically.

License
MIT
Use-case
If this project helps your robotics project, please let me know with creating an issue.
Your robot's video, which is using PythonRobotics, is very welcome!!
This is a list of user's comment and references:users_comments
Contribution
Any contribution is welcome!!
Please check this document:How To Contribute — PythonRobotics documentation
Citing
If you use this project's code for your academic work, we encourage you to cite our papers
If you use this project's code in industry, we'd love to hear from you as well; feel free to reach out to the developers directly.
Supporting this project
If you or your company would like to support this project, please consider:
If you would like to support us in some other way, please contact with creating an issue.
Sponsors
JetBrains
They are providing a free license of their IDEs for this OSS development.
1Password
They are providing a free license of their 1Password team license for this OSS project.
Authors

OpenPCDet
open-mmlab·Python
基于 PyTorch 的激光雷达 3D 目标检测工具箱,统一了 PointPillar、PV-RCNN 等主流点云检测模型的训练与评测流程,省去自己搭框架的麻烦。
3D目标检测+4自动驾驶
5765+31.5k2025-10-08 10:56 UTC
mrpt
MRPT·C++
一套面向移动机器人和自动驾驶的 C++ 工具库,提供 SLAM、计算机视觉、地图构建、粒子滤波和运动估计等模块,省去从零搭建底层算法。
移动机器人+4自动驾驶
2175+16623.6.22026-11-07 22:34 UTC
AutonomousVehicleControlBeginnersGuide
ShisatoYano·Python
用 Python 仿真加开源教材一步步搭建自动驾驶系统,可在同一框架里替换对比定位、规划与控制算法,适合入门学习。
自动驾驶+4自动驾驶
1938+23212026-11-08 08:38 UTC
PointCNN
yangyanli·Python
PointCNN 提出 X-变换卷积算子,直接在无序点云上做特征学习,可用于三维点云分类和分割,服务于自动驾驶、机器人等场景。
点云+4自动驾驶
1436358v1.02026-03-12 12:31 UTC