README 未给出直接安装命令,需按官网 setup 指南操作;依赖 ROS 2 环境(humble 或 jazzy)与 Python 3.10/3.12;部分功能需额外集成模型或仿真环境。
rai
RobotecAIApache-2.0活跃维护面向物理 AI 机器人的厂商无关智能体框架,基于 ROS 2 工具执行复杂动作、场景任务、自由接口调用、日志摘要和语音交互。
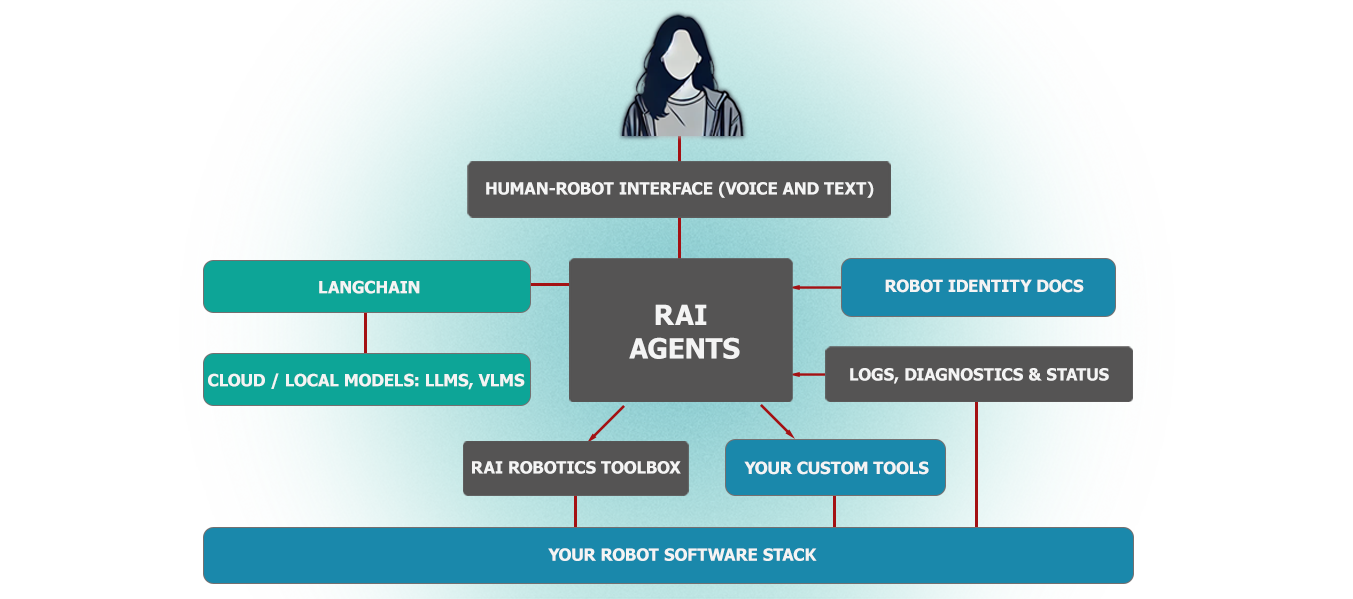
RAI is a vendor agnostic agentic framework for Physical AI robotics, utilizing ROS 2 tools to perform complex actions, defined scenarios, free interface execution, log summaries, voice interaction and more.
2.12.4发布于 2026-09-08 11:30 UTC615star +1 / 7 天79fork同步于 2026-11-10 11:57 UTC
详见官方快速安装指南:https://robotecai.github.io/rai/setup/install 硬件要求按 README 说明
README 未说明显存或 GPU 型号要求;仅标注支持 Ubuntu 22.04/24.04 与 ROS 2 humble/jazzy。
基于 ROS 2 的厂商无关具身智能体框架,让机器人执行复杂动作与语音交互
面向物理 AI 机器人的厂商无关智能体框架,基于 ROS 2 工具执行复杂动作、场景任务、自由接口调用、日志摘要和语音交互。
核心能力
- 用 ROS 2 工具执行复杂动作与预定义场景
- 支持自由接口执行与日志摘要
- 集成语音交互(ASR/TTS)与多模态输入输出
- 提供 rai_bench 基准测试套件评估智能体与模型
- 内置 rai_perception 开放集目标检测与 rai_nomad 导航集成
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
- 2.12.4最新正式版2026-09-08 · 2026-09-08 11:30 UTC
What's Changed
- fix(s2s): dispatch on the transcription model names the config uses by @maciejmajek in https://github.com/RobotecAI/rai/pull/873
- feat(nav2): add workspace bounds and coordinate safety validation by @ved197338 in https://github.com/RobotecAI/rai/pull/871
New Contributors
- @ved197338 made their first contribution in https://github.com/RobotecAI/rai/pull/871
Full Changelog: https://github.com/RobotecAI/rai/compare/2.12.3...2.12.4
- 2.12.32026-09-08 · 2026-09-08 10:57 UTC
查看更新说明
What's Changed
- fix: @Bartok9 contributions (batch 2) by @maciejmajek in https://github.com/RobotecAI/rai/pull/872
Full Changelog: https://github.com/RobotecAI/rai/compare/2.12.2...2.12.3
- 2.12.22026-09-08 · 2026-09-08 10:57 UTC
查看更新说明
What's Changed
- feat(rai_perception): setup time script for downloading weights by @maciejmajek in https://github.com/RobotecAI/rai/pull/791
- chore: remove unused sumbodule by @maciejmajek in https://github.com/RobotecAI/rai/pull/794
- fix: @Bartok9 contributions by @maciejmajek in https://github.com/RobotecAI/rai/pull/824
Full Changelog: https://github.com/RobotecAI/rai/compare/2.12.1...2.12.2
- 2.12.12026-09-08 · 2026-09-08 10:56 UTC
查看更新说明
What's Changed
- fix: O3DE manipulation benchmark determinism enhancements by @skalade in https://github.com/RobotecAI/rai/pull/789
New Contributors
- @skalade made their first contribution in https://github.com/RobotecAI/rai/pull/789
Full Changelog: https://github.com/RobotecAI/rai/compare/2.12.0...2.12.1
- 2.12.02.12.0 (langchain 1.x)2026-04-13 · 2026-04-13 11:54 UTC
查看更新说明
What's Changed
- feat: langchain 1.x by @cursor[bot] in https://github.com/RobotecAI/rai/pull/787
New Contributors
- @cursor[bot] made their first contribution in https://github.com/RobotecAI/rai/pull/787
Full Changelog: https://github.com/RobotecAI/rai/compare/2.11.2...2.12.0
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。
RAI
RAI is a flexible AI agent framework to develop and deploy Embodied AI features for your robots.
📚 Visit robotecai.github.io/rai for the latest documentation, setup guide and tutorials. 📚


🎯 Overview
| Category | Description | Features |
|---|---|---|
| 🤖 Multi-Agent Systems | Empowering robotics with advanced AI capabilities | • Seamlessly integrate Gen AI capabilities into your robots• Enable sophisticated agent-based architectures |
| 🔄 Robot Intelligence | Enhancing robotic systems with smart features | • Add natural human-robot interaction capabilities• Bring flexible problem-solving to your existing stack• Provide ready-to-use AI features out of the box |
| 🌟 Multi-Modal Interaction | Supporting diverse interaction capabilities | • Handle diverse data types natively• Enable rich sensory integration• Process multiple input/output modalities simultaneously |
RAI framework
- rai core: Core functionality for multi-agent system, human-robot interaction and multi-modalities.
- rai whoami: Tool to extract and synthesize robot embodiment information from a structured directory of documentation, images, and URDFs.
- rai_asr: Speech-to-text models and tools.
- rai_tts: Text-to-speech models and tools.
- rai_sim: Package for connecting RAI to simulation environments.
- rai_bench: Benchmarking suite for RAI. Test agents, models, tools, simulators, etc.
- rai_perception: Object detection tools based on open-set models and machine learning techniques.
- rai_nomad: Integration with NoMaD for navigation.
- rai_finetune: Finetune LLMs on your embodied data.
Getting started
See Quick setup guide.
Simulation demos
Try RAI yourself with these demos:
| Application | Robot | Description | Docs Link |
|---|---|---|---|
| Mission and obstacle reasoning in orchards | Autonomous tractor | In a beautiful scene of a virtual orchard, RAI goes beyond obstacle detection to analyze best course of action for a given unexpected situation. | link |
| Manipulation tasks with natural language | Robot Arm (Franka Panda) | Complete flexible manipulation tasks thanks to RAI and Grounded SAM 2 | link |
| Autonomous mobile robot demo | Husarion ROSbot XL | Demonstrate RAI's interaction with an autonomous mobile robot platform for navigation and control | link |
| Agentic mobile manipulator | RB-KAIROS | A comprehensive demo with on-board execution | link |
Community
Embodied AI Community Group
RAI is one of the main projects in focus of the Embodied AI Community Group. If you would like to join the next meeting, look for it in the ROS Community Calendar.
Publicity
- A talk about RAI at ROSCon 2024.
RAI Q&A
Please take a look at Q&A.
Developer Resources
See our documentation for a deeper dive into RAI, including instructions on creating a configuration specifically for your robot.
Contributing
You are welcome to contribute to RAI! Please see our Contribution Guide.
Citation
If you find our work helpful for your research, please consider citing the following BibTeX entry.
@misc{rachwał2025raiflexibleagentframework,
      title={RAI: Flexible Agent Framework for Embodied AI},
      author={Kajetan Rachwał and Maciej Majek and Bartłomiej Boczek and Kacper Dąbrowski and Paweł Liberadzki and Adam Dąbrowski and Maria Ganzha},
      year={2025},
      eprint={2505.07532},
      archivePrefix={arXiv},
      primaryClass={cs.MA},
      url={https://arxiv.org/abs/2505.07532},
}
Autoregressive-Models-in-Vision-Survey
ChaofanTao
系统梳理视觉自回归模型的研究综述(TMLR 2025),覆盖图像生成、多模态、点云、运动预测等方向,帮研究者快速理清技术脉络与加速方法。
视觉自回归+4具身智能 / VLA
805232026-05-05 15:14 UTC
RoboBrain
FlagOpen·Python
面向机器人操作任务的统一大脑模型,把抽象指令逐步落到具体动作,配套官方推理代码,可直接用于具身智能研究。
具身智能+4具身智能 / VLA
568442025-10-13 04:14 UTC
Awesome-Embodied-AI
haoranD
整理具身智能方向的论文与行业资源清单,覆盖检测、导航、语言学习等主题,方便快速定位相关研究。
具身智能+4具身智能 / VLA
539292025-06-03 15:13 UTC
VAGEN
mll-lab-nu·Python
面向多轮视觉语言模型智能体的世界模型强化学习框架,让 VLM Agent 在交互中通过 RL 训练提升多轮决策能力。
世界模型+4具身智能 / VLA
522+263v25.12.302026-10-29 10:15 UTC