需先手动安装 Sophus 并切到 a621ff 提交,且 Vikit 要用 rpg_vikit 而非 fast-livo1 的版本;运行示例需自行下载 FAST-LIVO2-Dataset 数据集;依赖 PCL>=1.8、Eigen>=3.3.4、OpenCV>=4.2,版本不足会编译失败。
FAST-LIVO2
hku-marsGPL-2.0更新放缓面向机器人与无人机的激光雷达-惯性-视觉紧耦合里程计,实时输出高精度位姿与彩色点云,支撑三维重建与SLAM。
FAST-LIVO2: Fast, Direct LiDAR-Inertial-Visual Odometry
暂无版本4,866star +18 / 7 天890fork同步于 2026-11-11 11:36 UTC
cd ~/catkin_ws/src
git clone https://github.com/hku-mars/FAST-LIVO2
cd ../
catkin_make
source ~/catkin_ws/devel/setup.bash 硬件要求按 README 说明
README 未说明具体显存或 GPU 型号要求;软件环境要求 Ubuntu 18.04~20.04 与 ROS。
激光-惯性-视觉紧耦合里程计,在退化环境下做实时定位与建图
面向机器人与无人机的激光雷达-惯性-视觉紧耦合里程计,实时输出高精度位姿与彩色点云,支撑三维重建与SLAM。
核心能力
- 紧耦合融合 LiDAR、IMU 与相机做直接法里程计
- 面向严重退化环境提供实时三维重建与机载定位
- 开源硬同步手持设备方案含 CAD 与 STM32 源码
- 配套 FAST-LIVO2-Dataset 与 FAST-Calib 外参标定工具
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
暂无 release 数据(可能没有发版,或尚未同步)。
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。
FAST-LIVO2
FAST-LIVO2: Fast, Direct LiDAR-Inertial-Visual Odometry
📢 News
- 🔓 2025-01-23: Code released!
- 🎉 2024-10-01: Accepted by T-RO '24!
- 🚀 2024-07-02: Conditionally accepted.
📬 Contact
For further inquiries or assistance, please contact [email protected].
1. Introduction
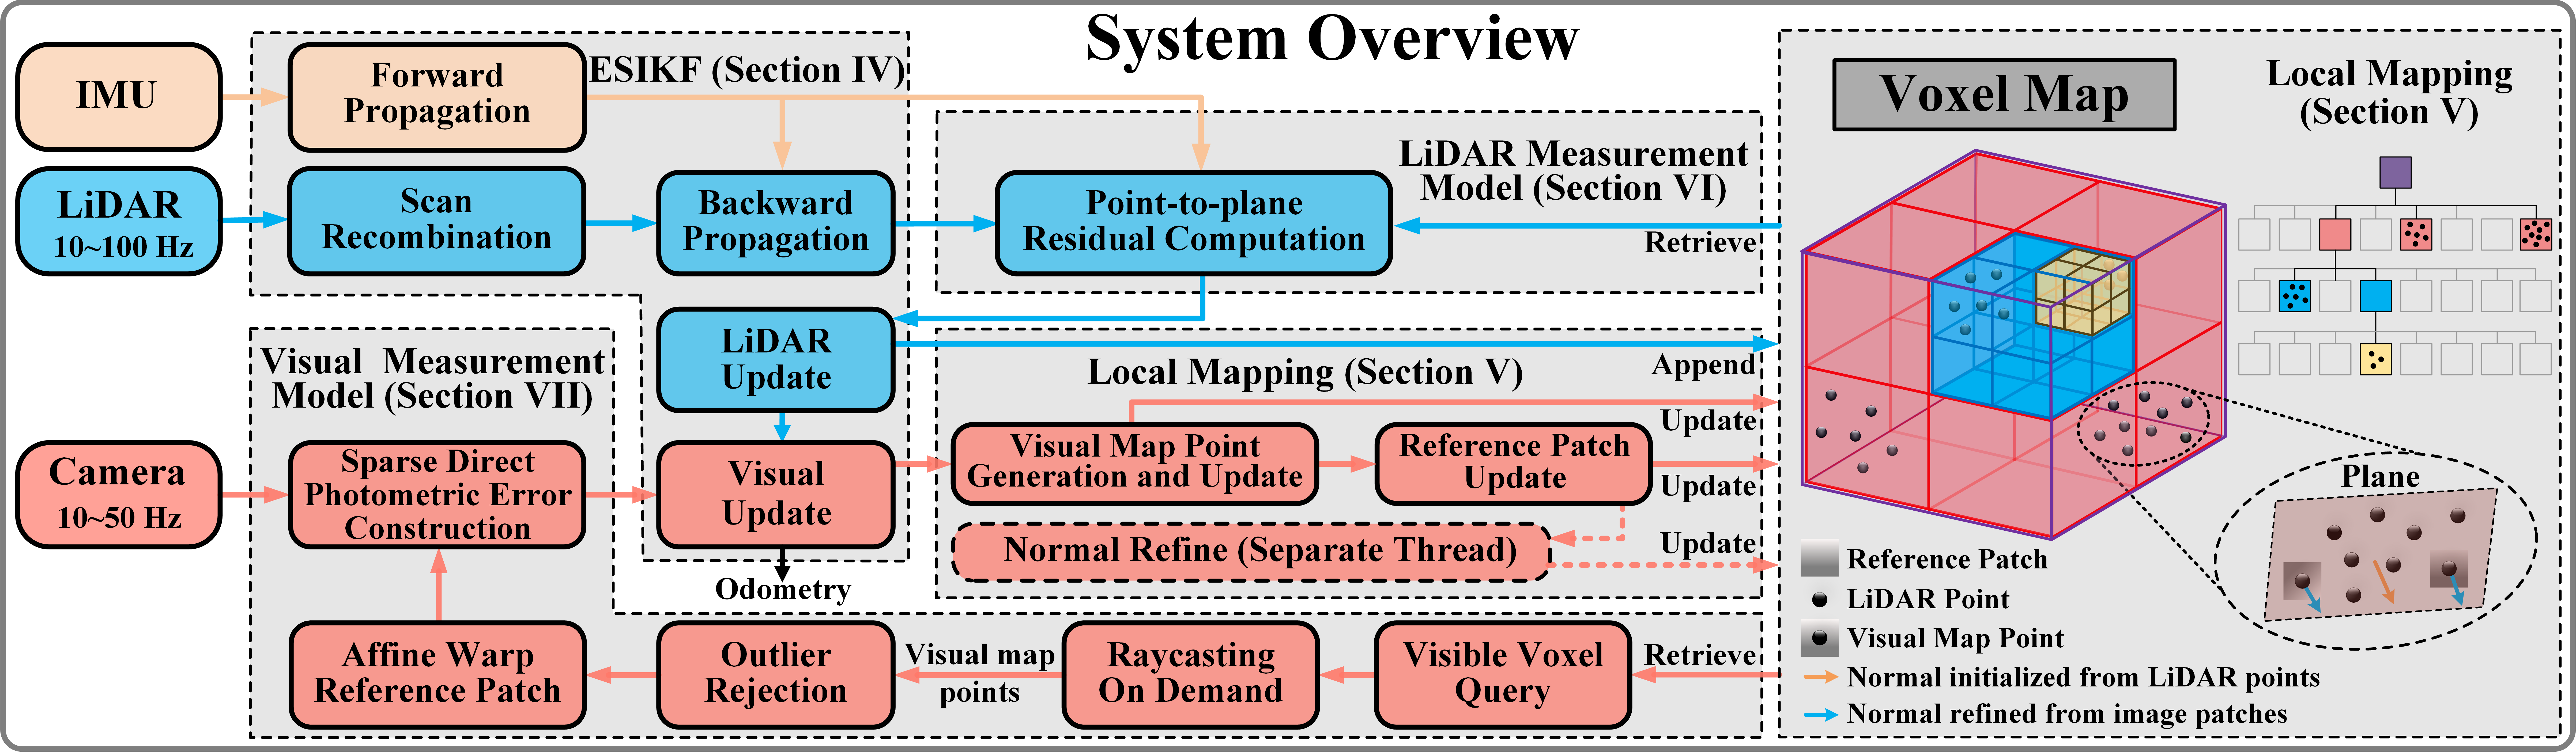
FAST-LIVO2 is an efficient and accurate LiDAR-inertial-visual fusion localization and mapping system, demonstrating significant potential for real-time 3D reconstruction and onboard robotic localization in severely degraded environments.
Developer: Chunran Zheng 郑纯然
1.1 Related video
Our accompanying video is now available on Bilibili and YouTube.
1.2 Related paper
FAST-LIVO2: Fast, Direct LiDAR-Inertial-Visual Odometry
FAST-LIVO2 on Resource-Constrained Platforms
FAST-LIVO: Fast and Tightly-coupled Sparse-Direct LiDAR-Inertial-Visual Odometry
FAST-Calib: LiDAR-Camera Extrinsic Calibration in One Second
1.3 Our hard-synchronized equipment
We open-source our handheld device, including CAD files, synchronization scheme, STM32 source code, wiring instructions, and sensor ROS driver. Access these resources at this repository: LIV_handhold.
1.4 Our associate dataset: FAST-LIVO2-Dataset
Our associate dataset FAST-LIVO2-Dataset used for evaluation is also available online.
1.5 Our LiDAR-camera calibration method
The FAST-Calib toolkit is recommended. Its output extrinsic parameters can be directly filled into the YAML file.
2. Prerequisited
2.1 Ubuntu and ROS
Ubuntu 18.04~20.04. ROS Installation.
2.2 PCL && Eigen && OpenCV
PCL>=1.8, Follow PCL Installation.
Eigen>=3.3.4, Follow Eigen Installation.
OpenCV>=4.2, Follow Opencv Installation.
2.3 Sophus
Sophus Installation for the non-templated/double-only version.
git clone https://github.com/strasdat/Sophus.git
cd Sophus
git checkout a621ff
mkdir build && cd build && cmake ..
make
sudo make install
2.4 Vikit
Vikit contains camera models, some math and interpolation functions that we need. Vikit is a catkin project, therefore, download it into your catkin workspace source folder.
# Different from the one used in fast-livo1
cd catkin_ws/src
git clone https://github.com/xuankuzcr/rpg_vikit.git
3. Build
Clone the repository and catkin_make:
cd ~/catkin_ws/src
git clone https://github.com/hku-mars/FAST-LIVO2
cd ../
catkin_make
source ~/catkin_ws/devel/setup.bash
4. Run our examples
Download FAST-LIVO2-Dataset from Global-LVBA Section IV.
roslaunch fast_livo mapping_avia.launch
rosbag play YOUR_DOWNLOADED.bag
5. License
The source code of this package is released under the GPLv2 license. For commercial use, please contact me at [email protected] and Prof. Fu Zhang at [email protected] to discuss an alternative license.

gaussian-splatting
graphdeco-inria·Python
3D Gaussian Splatting 的官方参考实现,用高斯点云做辐射场重建,实现实时可交互的逼真场景渲染。
3D高斯泼溅+43D 重建硬核
24457+253.5k2025-10-17 14:28 UTC
instant-ngp
NVlabs·Cuda
用多分辨率哈希编码把 NeRF、SDF 等神经图形基元的训练从几小时压到几秒,实时渲染三维场景。
神经辐射场+43D 重建硬核
17595+72.1kv2.02026-02-02 12:32 UTC
Open3D
isl-org·C++
Open3D 是一个现代 3D 数据处理库,提供点云、网格、RGB-D 和 3D 可视化等算法与工具,支持 C++ 和 Python,可用于 3D 感知、重建与机器学习研究。
3D数据处理+43D 重建进阶
14194+132.6kv0.20.02026-11-11 00:13 UTC
colmap
colmap·C++
从多张照片重建三维场景的 C++ 工具,集成了运动恢复结构(SfM)和多视图立体(MVS),可输出相机位姿与稠密点云。
三维重建+43D 重建进阶
13200+262.2kdatasets-eth3d-undistorted-v12026-11-10 08:51 UTC