完整 SplatAD 模型(含数据加载、解码器等)尚未在本仓库发布,需等待 neurad-studio;本仓库只含渲染组件,安装依赖需按 gsplat 文档自行配置 CUDA 环境
splatad
carlindsApache-2.0长期未更新用 3D 高斯泼溅实现自动驾驶场景下激光雷达与相机数据的实时渲染,为感知算法提供高保真仿真环境。
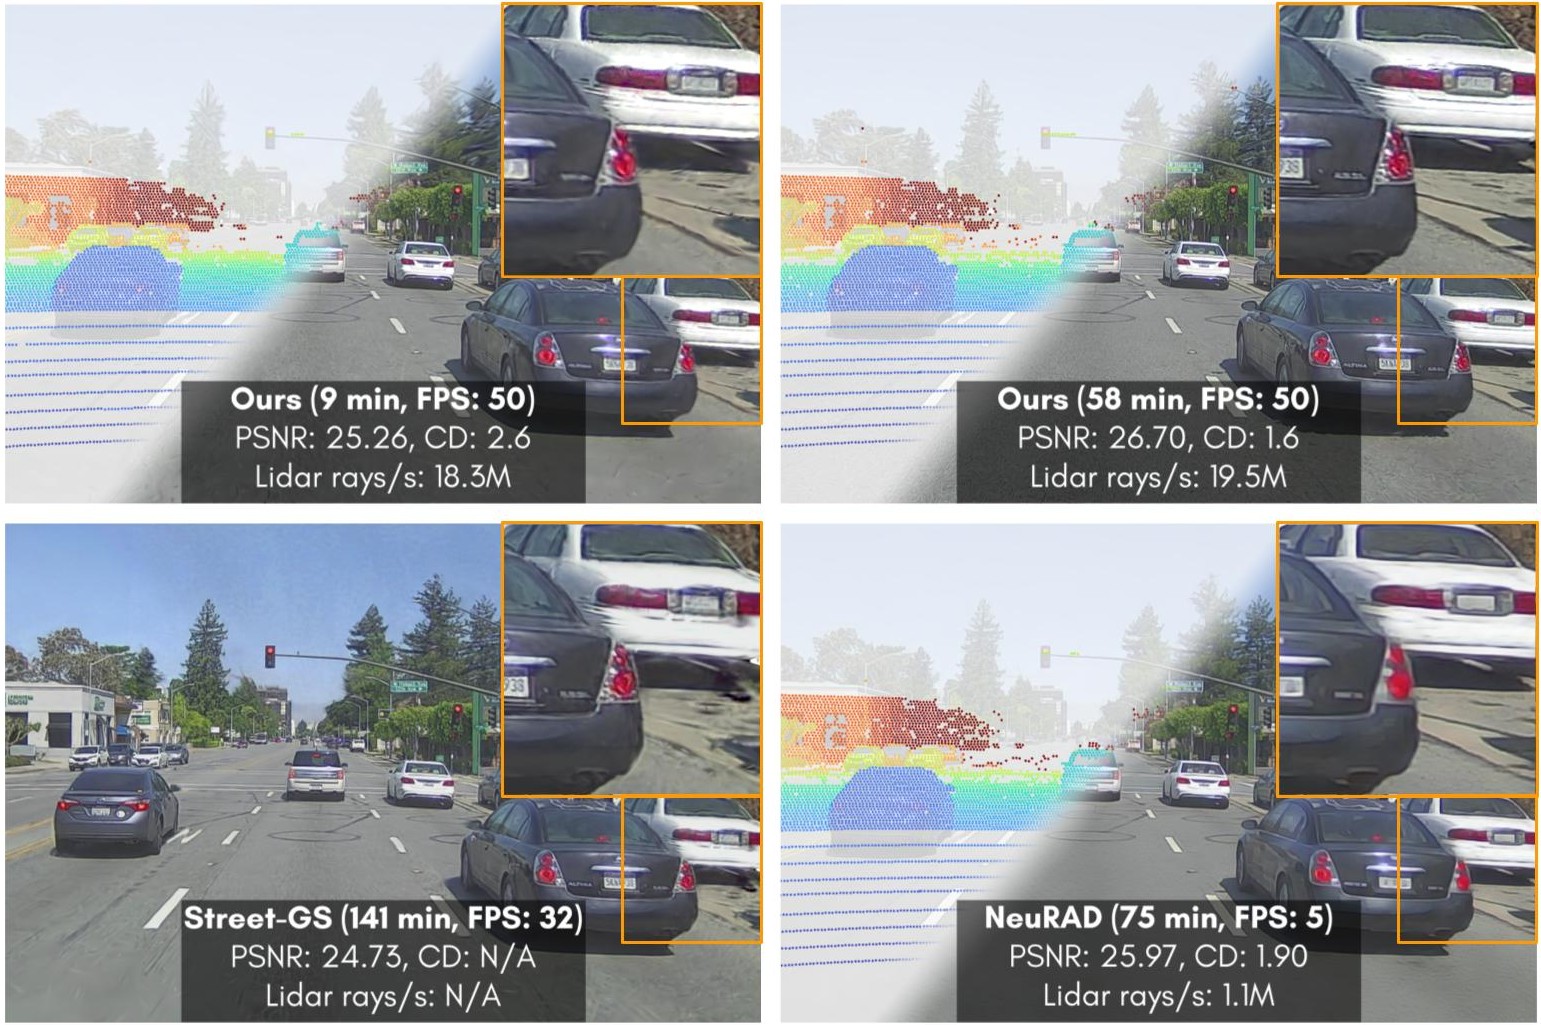
SplatAD: Real-Time Lidar and Camera Rendering with 3D Gaussian Splatting for Autonomous Driving
暂无版本433star34fork同步于 2026-11-07 07:30 UTC
参照 gsplat 官方安装文档:https://github.com/nerfstudio-project/gsplat#installation 硬件要求按 README 说明
README 未说明具体显存与 GPU 型号要求,仅说明基于 gsplat 的 CUDA 加速光栅化,安装与开发环境需参照 gsplat 文档
需要 CUDA
基于 3D 高斯泼溅的自动驾驶激光雷达与相机实时渲染代码库
用 3D 高斯泼溅实现自动驾驶场景下激光雷达与相机数据的实时渲染,为感知算法提供高保真仿真环境。
核心能力
- 将激光雷达点投影到球面坐标后做深度与特征光栅化
- 支持非线性格点上的激光雷达光栅化
- 为相机与激光雷达提供卷帘快门补偿
- 提供激光雷达渲染与卷帘快门补偿的示例 notebook
- 基于 gsplat 扩展,无额外依赖
容易踩的坑
内容由模型根据 README 生成,可能不完整或不准确,以官方文档为准。看原文 README
暂无 release 数据(可能没有发版,或尚未同步)。
用户点评
登录用户的真实使用记录,可按版本和硬件筛选共 0 条
还没有人点评。第一个说出真实体验的人最有价值。
About
This is the official repository for the CVPR 2025 paper SplatAD: Real-Time Lidar and Camera Rendering with 3D Gaussian Splatting for Autonomous Driving. The code in this repository builds upon the open-source library gsplat, with modifications and extensions designed for autonomous driving data.
While the code contians all components needed to efficiently render camera and lidar data, the SplatAD-model itself, including dataloading, decoders, etc., will be released through neurad-studio.
We welcome all contributions!
Key Features
- Efficient lidar rendering
- Projection to spherical coordinates
- Depth and feature rasterization for a non-linear grid of points
- Rolling shutter compensation for camera and lidar
Installation
Our code introduce no additional dependencies. We thus refer to the original documentation from gsplat for both installation and development setup.
Usage
See rasterization and lidar_rasterization for entry points to camera and lidar rasterization.
Additionally, we provide example notebooks under examples that demonstrate lidar rendering and rolling shutter compensation.
For further examples, check out the test files.
Built On
- gsplat - Collaboration friendly library for CUDA accelerated rasterization of Gaussians with python bindings
- 3dgs-deblur - Inspiration for the rolling shutter compensation
Citation
You can find our paper on arXiv.
If you use this code or find our paper useful, please consider citing:
@article{hess2024splatad,
  title={SplatAD: Real-Time Lidar and Camera Rendering with 3D Gaussian Splatting for Autonomous Driving},
  author={Hess, Georg and Lindstr{\"o}m, Carl and Fatemi, Maryam and Petersson, Christoffer and Svensson, Lennart},
  journal={arXiv preprint arXiv:2411.16816},
  year={2024}
}
Contributors

gaussian-splatting
graphdeco-inria·Python
3D Gaussian Splatting 的官方参考实现,用高斯点云做辐射场重建,实现实时可交互的逼真场景渲染。
3D高斯泼溅+43D 重建
24452+203.5k2025-10-17 14:28 UTC
instant-ngp
NVlabs·Cuda
用多分辨率哈希编码把 NeRF、SDF 等神经图形基元的训练从几小时压到几秒,实时渲染三维场景。
神经辐射场+43D 重建
17593+52.1kv2.02026-02-02 12:32 UTC
Open3D
isl-org·C++
Open3D 是一个现代 3D 数据处理库,提供点云、网格、RGB-D 和 3D 可视化等算法与工具,支持 C++ 和 Python,可用于 3D 感知、重建与机器学习研究。
3D数据处理+43D 重建
14192+112.6kv0.20.02026-11-05 18:33 UTC
colmap
colmap·C++
从多张照片重建三维场景的 C++ 工具,集成了运动恢复结构(SfM)和多视图立体(MVS),可输出相机位姿与稠密点云。
三维重建+43D 重建
13196+222.2kdatasets-eth3d-undistorted-v12026-11-10 08:51 UTC